Skip to content
CHINA ROBOTICS SUPPLY CHAIN · PROTOTYPES TO 500 UNITS · ENGINEERING RESPONSE WITHIN 1 BUSINESS DAY
Robot Dexterous Hands & Grippers
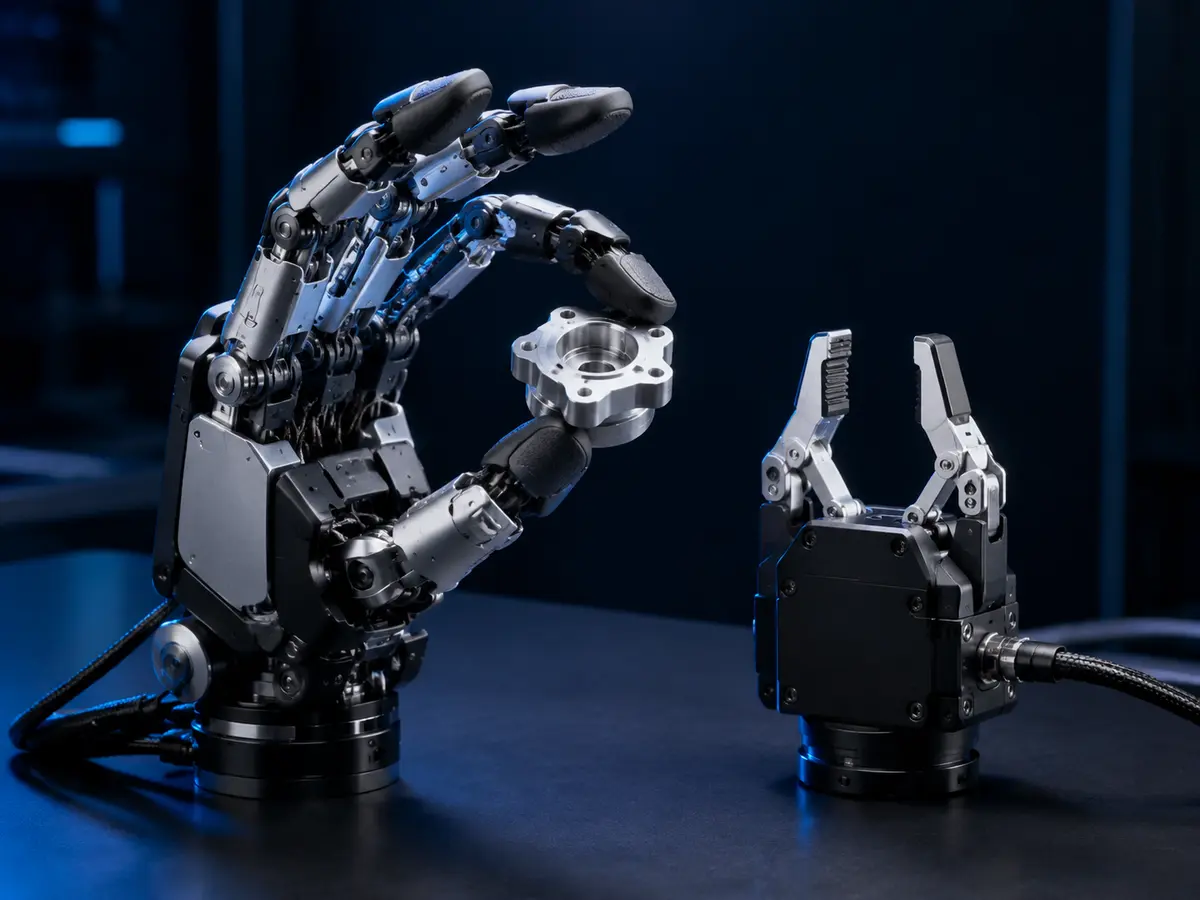
Source dexterous robot hands, adaptive electric grippers, end effectors and tool changers from Chinese manufacturers for humanoid and industrial robot prototypes.
Products we source
- Five-finger dexterous hands
- Adaptive electric grippers
- Two and three-finger grippers
- Tool changers
- Tactile fingertips
- Custom end effectors
Robot applications
Supplier matching starts with the system requirement, not a generic catalogue.
01Humanoid manipulation research
Compared on technical fit, prototype access, documentation, capacity and export readiness.
02Warehouse picking and sorting
Compared on technical fit, prototype access, documentation, capacity and export readiness.
03Laboratory automation
Compared on technical fit, prototype access, documentation, capacity and export readiness.
04Service robot tool handling
Compared on technical fit, prototype access, documentation, capacity and export readiness.
What we need to quote
Complete inputs produce comparable quotations and prevent price changes after sampling.
Payload and gripping force
State the requirement and acceptable range where known.
Stroke and finger count
State the requirement and acceptable range where known.
Target object set
State the requirement and acceptable range where known.
Control interface and SDK
State the requirement and acceptable range where known.
Weight and envelope
State the requirement and acceptable range where known.
Prototype and annual volume
State the requirement and acceptable range where known.
Prototype sourcing data
| Product type | Sample MOQ | Indicative lead time |
|---|
| Electric gripper | 1 pc | 1–3 weeks |
| Dexterous hand | 1 pc | 2–6 weeks |
| Custom end effector | 1–3 pcs | 3–8 weeks |
Engineering note: A hand is only useful when mechanics, protocol, SDK and spare-part support fit your development stack.
Robot hands and grippers sourcing FAQ
Can I buy one dexterous robot hand?
Several Chinese suppliers accept one research or prototype unit, depending on configuration and support.
Which interfaces are available?
CAN, RS485, EtherCAT and USB are common, but SDK quality varies significantly.
Can you source tactile fingertips?
Yes, either integrated with the hand or as separate tactile arrays.
Send one line and see what comes back.
You do not need a finished BOM. Send the component currently blocking your build and we will tell you what we can source.